Robot Navigation
Autonomous navigation systems for mobile robots in complex, dynamic environments. Classical planning to learning-based approaches.
Key Skills & Technologies
Related Projects
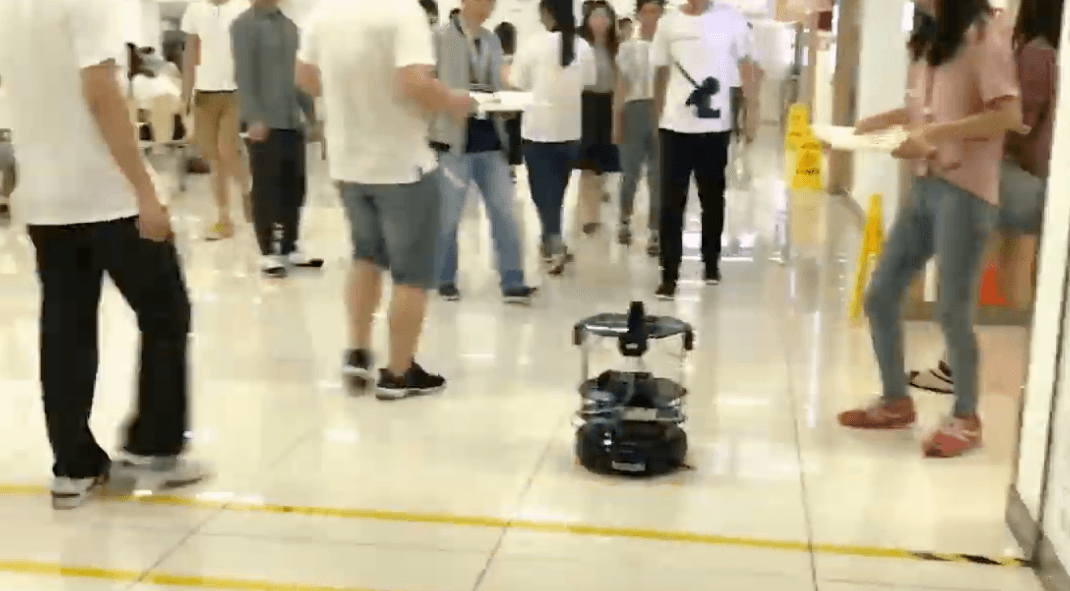
ArenaNav v4 – Core Platform
Fourth version of our core development and benchmarking platform. Always looking for students to contribute and participate in papers.
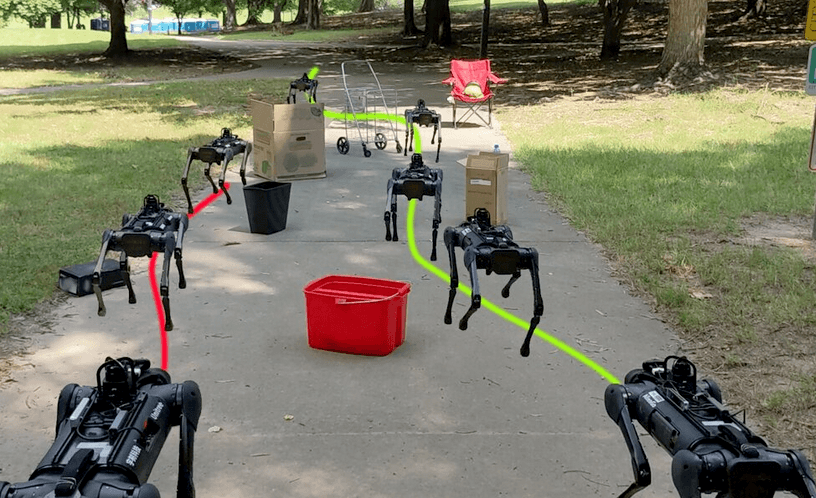
Quadrupeds in Crowded Environments
Integration of quadrupeds into ArenaNav. Goal: deploy real quadruped robots at NUS campus and food centers!
Related Publications
Arena-Rosnav: Towards Deployment of Deep-RL-Based Obstacle Avoidance into Conventional Autonomous Navigation Systems
Linh Kästner, Teham Buiyan, Xinlin Zhao, Lei Jiao, Zhengcheng Shen, Tuan Anh Le and Jens Lambrecht
Arena2D - Deep-RL-Based Navigation in Highly Dynamic Environments
Linh Kästner, Cornelius Marx, Jens Lambrecht
All-in-One: A DRL-based Control Switch Combining State-of-the-art Navigation Planners
Linh Kästner, Johannes Cox, Teham Buiyan, Jens Lambrecht
Change-Robust Online Topological Memory for Long-Term Relocalization and Semantic Navigation
Jiaming Wang, Jizhuo Chen, Diwen Liu, Atharva Ghotavadekar, Jiaxuan Da, Linh Kästner, Harold Soh
TOPO-Bench: An Open-Source Topological Mapping Evaluation Framework with Quantifiable Perceptual Aliasing
Jiaming Wang, Jizhuo Chen, Diwen Liu, Jiaxuan Da, Jiamo Hu, Zhiwei Xue, Linh Kästner, Harold Soh
Interested in Robot Navigation?
We are looking for motivated researchers. Apply now to work on this topic.