Simulation & Digital Twins
High-fidelity simulation environments for training and evaluating robot behaviors. Bridging the sim-to-real gap.
Key Skills & Technologies
Related Projects
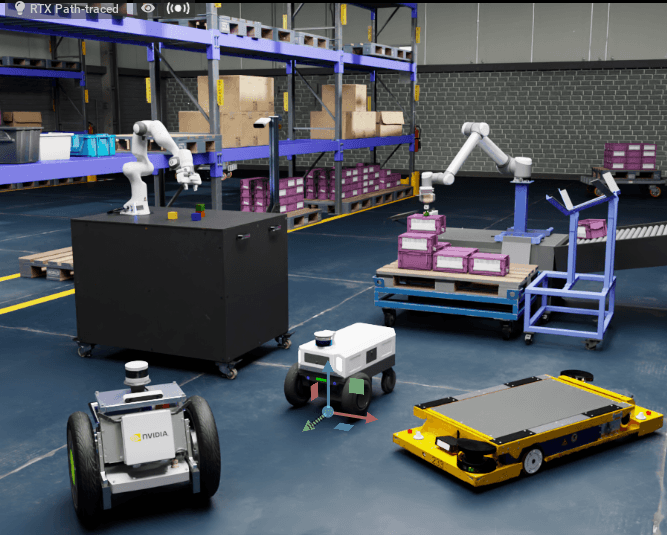
Photorealistic Simulation
Integration of ISAAC Gym simulation into ArenaNav and development of multimodal training approaches for navigation in crowds.
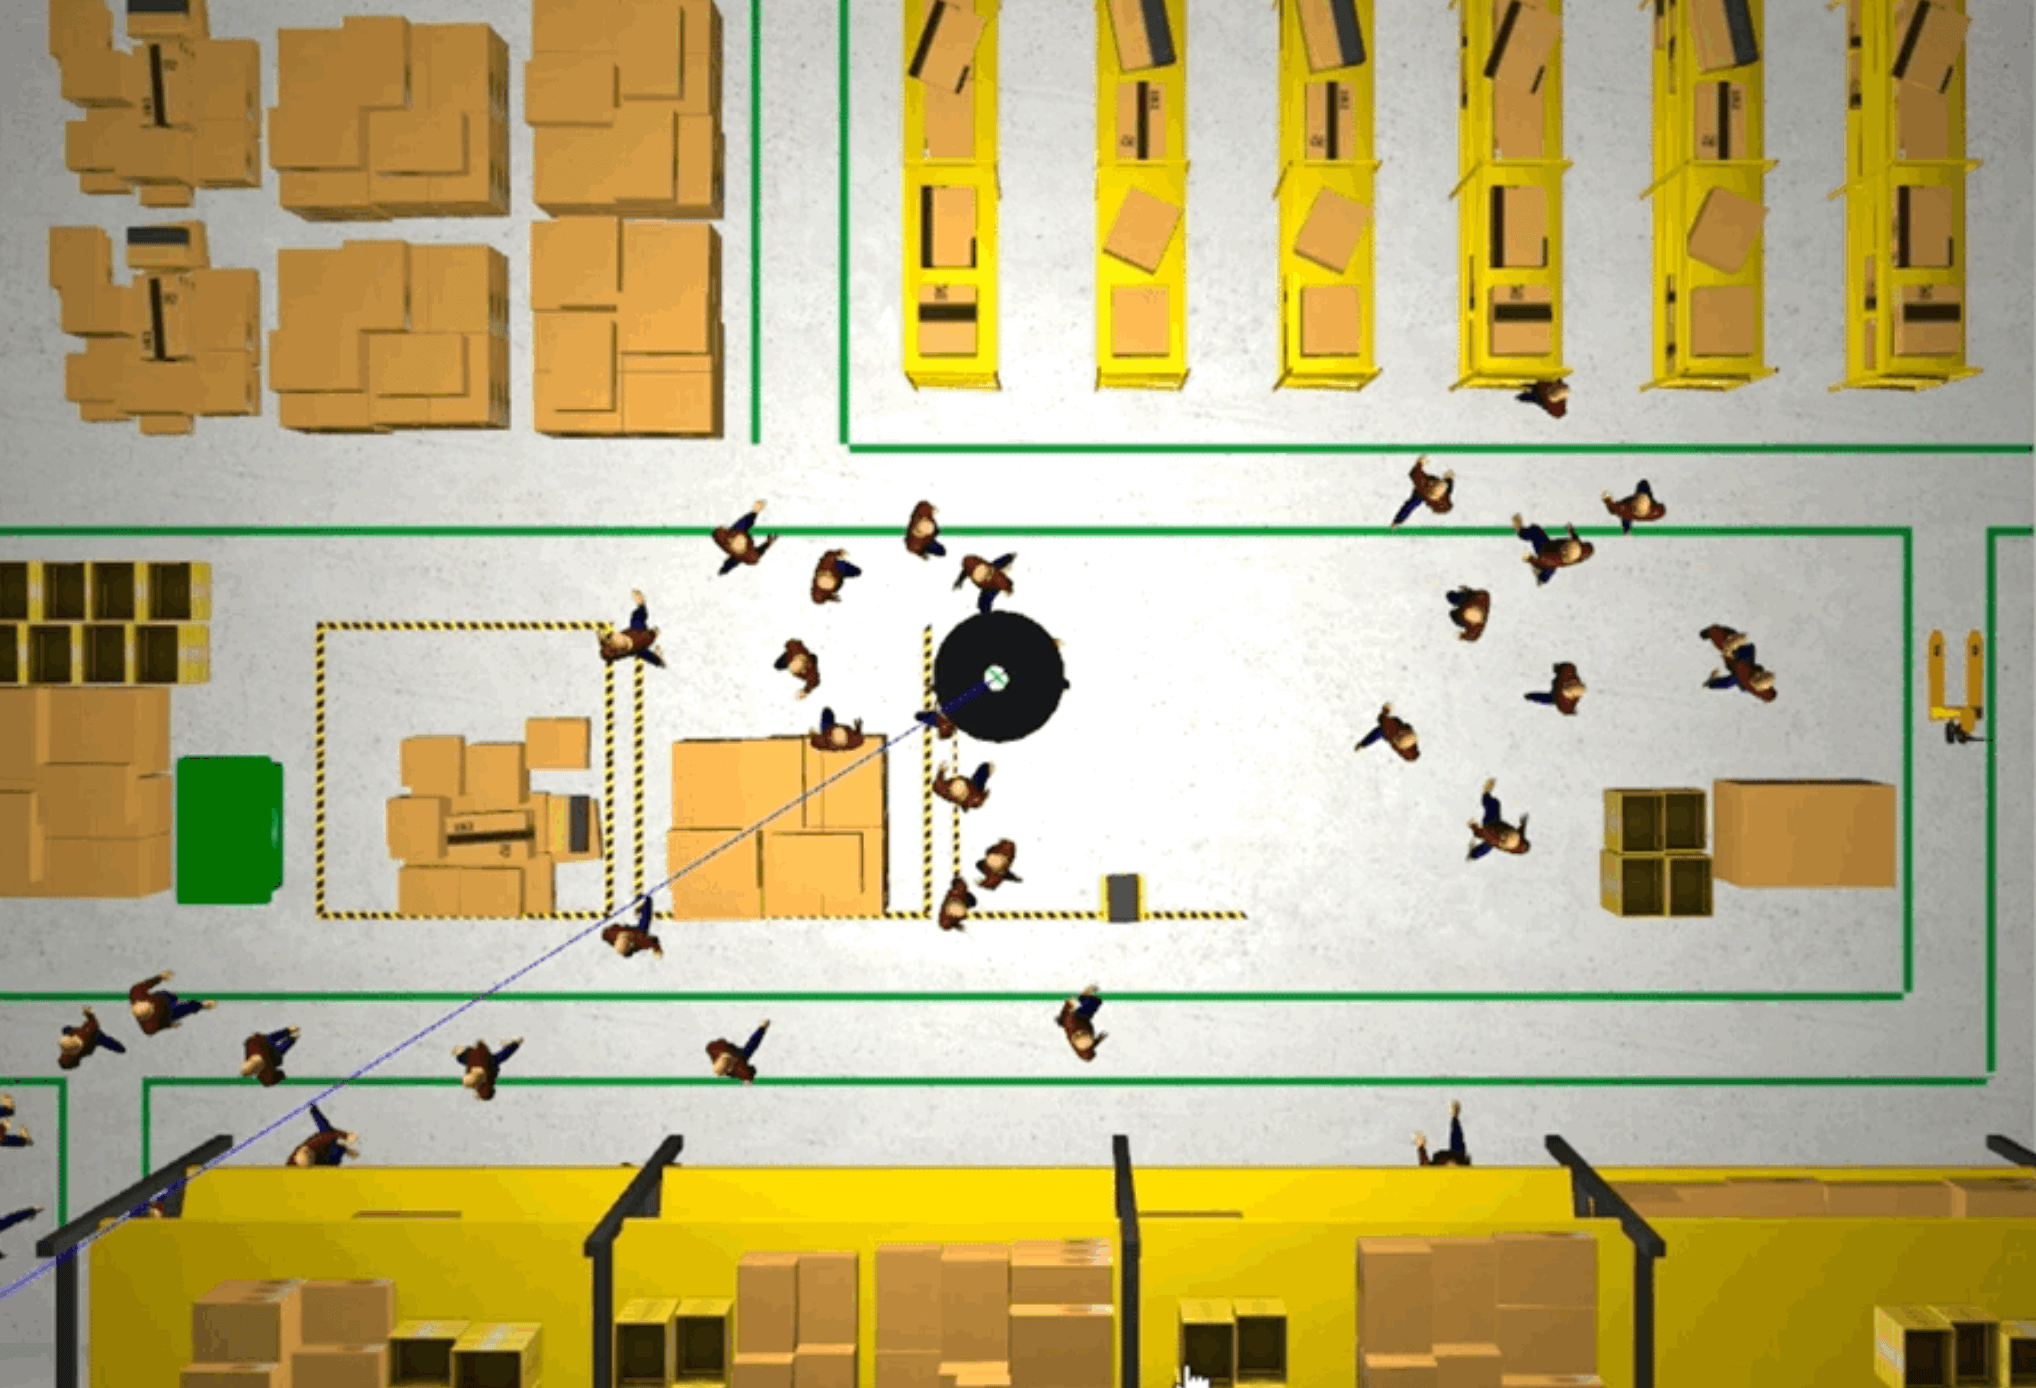
LLM-based World Generation
Leveraging LLMs to dynamically generate millions of randomized worlds for training and benchmarking.
Related Publications
Arena2D - Deep-RL-Based Navigation in Highly Dynamic Environments
Linh Kästner, Cornelius Marx, Jens Lambrecht
GROVE: Grounded Pedestrian Simulation via Natural Language for Interactive Social Robot Navigation
Duc Tai Nguyen, Volodymyr Shcherbyna, Anh Do Duc, Zhengcheng Shen, Teham Buiyan, Linh Kästner
D3D-GEN: Robot-Aware Domain-Grounded Interactive 3D World Generation for Social Robotics
Anh Duc Do, Volodymyr Shcherbyna, Tai Duc Nguyen, Spaarsh Thakkar, Zhengcheng Shen, Teham Buiyan, Archan Misra, Linh Kästner
PEDS: Closed-Loop Benchmarking of Social Navigation across Pedestrian Behavior Models
Duc Tai Nguyen, Volodymyr Shcherbyna, Anh Do Duc, Zhengcheng Shen, Linh Kästner
Arena-Rosnav 5.0: A Photorealistic ROS2 Simulation Framework for Developing and Benchmarking Social Navigation
Volodymyr Shcherbyna, Linh Kästner, Huajian Zeng, Giang Nguyen Huu Truong, Tim Lenz, Nam Truong Tran, Ahmed Martban, and Harold Soh
Interested in Simulation & Digital Twins?
We are looking for motivated researchers. Apply now to work on this topic.