Social Navigation
Robots navigating among humans in a socially compliant manner. Understanding human motion patterns and social norms.
Key Skills & Technologies
Related Projects
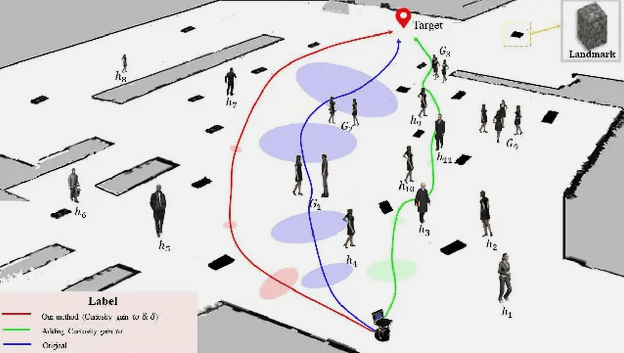
Robot Behavior Adaptation via Semantic Mapping
Navigation and behavior adaption for mobile robots based on semantic mapping and social interactions.
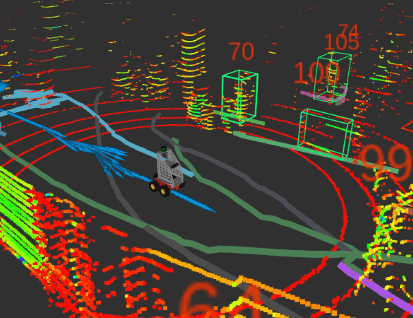
Human Detection and Tracking (RGB-D)
Computer vision for human detection, tracking, action and social state detection communicated via ROS.
Related Publications
Arena-Rosnav: Towards Deployment of Deep-RL-Based Obstacle Avoidance into Conventional Autonomous Navigation Systems
Linh Kästner, Teham Buiyan, Xinlin Zhao, Lei Jiao, Zhengcheng Shen, Tuan Anh Le and Jens Lambrecht
Arena2D - Deep-RL-Based Navigation in Highly Dynamic Environments
Linh Kästner, Cornelius Marx, Jens Lambrecht
Arena-Rosnav 3.0: Advancing Social Navigation in Collaborative and Highly Dynamic Environments
Linh Kästner, Volodymyr Shcherbyna, Huajian Zeng, Tuan Anh Le, Maximilian Ho-Kyoung Schreff, Halid Osmaev, Nam Truong Tran, Diego Diaz, Jan Golebiowski, Harold Soh, Jens Lambrecht
All-in-One: A DRL-based Control Switch Combining State-of-the-art Navigation Planners
Linh Kästner, Johannes Cox, Teham Buiyan, Jens Lambrecht
GROVE: Grounded Pedestrian Simulation via Natural Language for Interactive Social Robot Navigation
Duc Tai Nguyen, Volodymyr Shcherbyna, Anh Do Duc, Zhengcheng Shen, Teham Buiyan, Linh Kästner
Interested in Social Navigation?
We are looking for motivated researchers. Apply now to work on this topic.