*We're actively recruiting for Fall 2026.View positions
← Back to Team
Teham Buiyan

Teham Buiyan

Postdoctoral Researcher

teham@smu.edu.sg

Previously: PhD at TU Berlin

About

Specializing in multi-agent systems and deep reinforcement learning for collaborative robotics.

Research Interests

Multi-Agent RLCollaborationRobot Teams

Mentored by

Linh Kästner

Publications (7)

0 as first author7 as co-author

Co-authored papers (7)
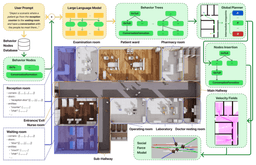
D3D-GEN: Robot-Aware Domain-Grounded Interactive 3D World Generation for Social Robotics

Anh Duc Do, Volodymyr Shcherbyna, Tai Duc Nguyen, Spaarsh Thakkar, Zhengcheng Shen, Teham Buiyan, Archan Misra, Linh Kästner

IEEE/RSJ IROS 2026, Pittsburgh, USA2026-09-27

GROVE: Grounded Pedestrian Simulation via Natural Language for Interactive Social Robot Navigation

Duc Tai Nguyen, Volodymyr Shcherbyna, Anh Do Duc, Zhengcheng Shen, Teham Buiyan, Linh Kästner

IEEE/RSJ IROS 2026, Pittsburgh, USA2026-09-27

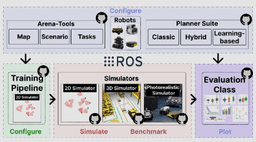
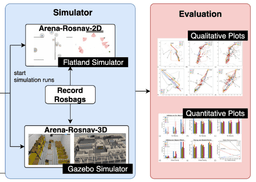
Arena-Rosnav 2.0: A Development and Benchmarking Platform for Robot Navigation in Highly Dynamic Environments

Linh Kästner, Reyk Carstens, Huajian Zeng, Jacek Kmiecik, Tuan Anh Le, Teham Bhuiyan, Boris Meinardus, Jens Lambrecht

IEEE/RSJ IROS 2023, Detroit, USA2023-06-01

Arena-Bench: A Benchmarking Suite for Obstacle Avoidance Approaches on Highly Dynamic Environments

Linh Kästner, Teham Buiyan, Tuan Anh Le, Reyk Carstens, Duc Pichel, Jacek Kmiecik, Elias Treis, Boris Meinardus, Bassel Fatloun, Niloufar Khorsadhi, Jens Lambrecht

IEEE RA-L + IROS 2022, Kyoto, Japan2022-10-01
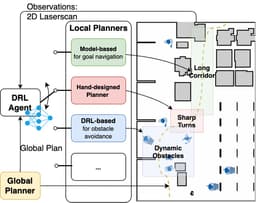
All-in-One: A DRL-based Control Switch Combining State-of-the-art Navigation Planners

Linh Kästner, Johannes Cox, Teham Buiyan, Jens Lambrecht

IEEE ICRA 2022, Philadelphia, USA2022-05-01

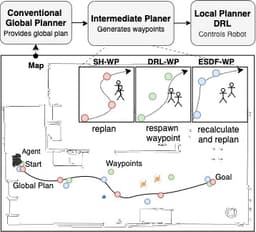
Connecting Deep-RL-based Obstacle Avoidance with Conventional Global Planners using Waypoint Generators

Linh Kästner, Teham Buiyan, Xinlin Zhao, Zhengcheng Shen, Jens Lambrecht

IEEE/RSJ IROS 2021, Prague, Czech Republic2021-06-01

Arena-Rosnav: Towards Deployment of Deep-RL-Based Obstacle Avoidance into Conventional Autonomous Navigation Systems

Linh Kästner, Teham Buiyan, Xinlin Zhao, Lei Jiao, Zhengcheng Shen, Tuan Anh Le and Jens Lambrecht

IEEE/RSJ IROS 2021, Prague, Czech Republic2021-06-01

Interested in collaborating?

Reach out to Teham Buiyan or apply to join ARENA Lab.